Research in progress
LeRobot · ACT · π0 / π0.5 · Piper
An experimental framework for robot manipulation with vision and touch. Extends LeRobot with Piper data collection and explores tactile policy inputs and residual action correction, with FTP-1 and DreamTacVLA prototypes.
Repository
Ongoing development
Isaac Sim · Isaac Lab · UIPC
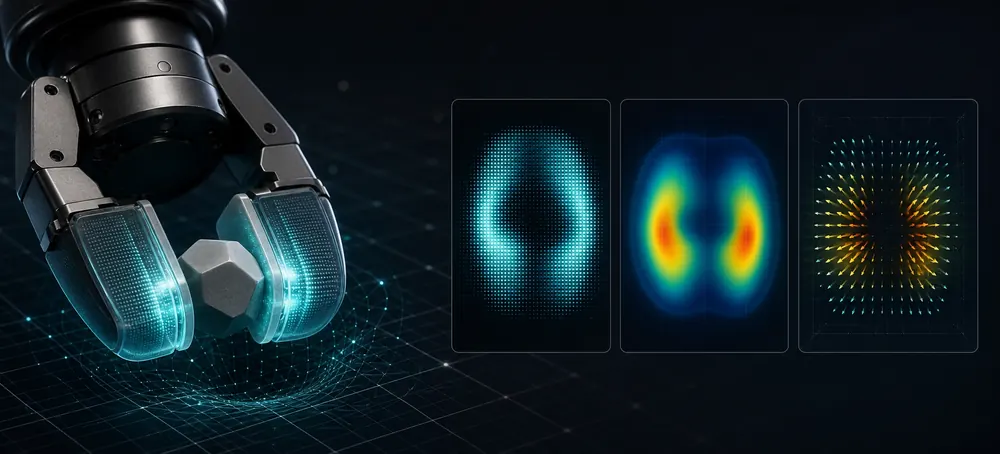
A tactile simulation platform for robot contact tasks. Uses Isaac Sim, Isaac Lab, and UIPC to model compliant membrane deformation and generate tactile images and force fields, with extensible robot, sensor, and object setups.
Repository
Tactile Images · Physical Measurements · Tactile Recognition
A tactile recognition model combining tactile image sequences with six calibrated physical signals. Uses feature fusion and temporal modeling, and provides tools for data collection, training, offline inference, and real-time recognition.
Repository
Dense Optical Flow · ONNX · RKNN · RK3588 · RV1126B
A compact dense optical-flow network for visuotactile sensing. Estimates image displacement through magnitude estimation, direction reconstruction, and residual refinement, with tools for export, quantization, and multi-stream inference on RK3588 and RV1126B.
Model / Deployment tools
Medical Imaging · 3D Imaging Reconstruction · Model Evaluation
A local bilingual desktop workbench for learning and research in medical imaging. Combines image viewing, CT reconstruction experiments, model inference, and evaluation, with offline core workflows, guided lessons, and an optional AI assistant.
Repository